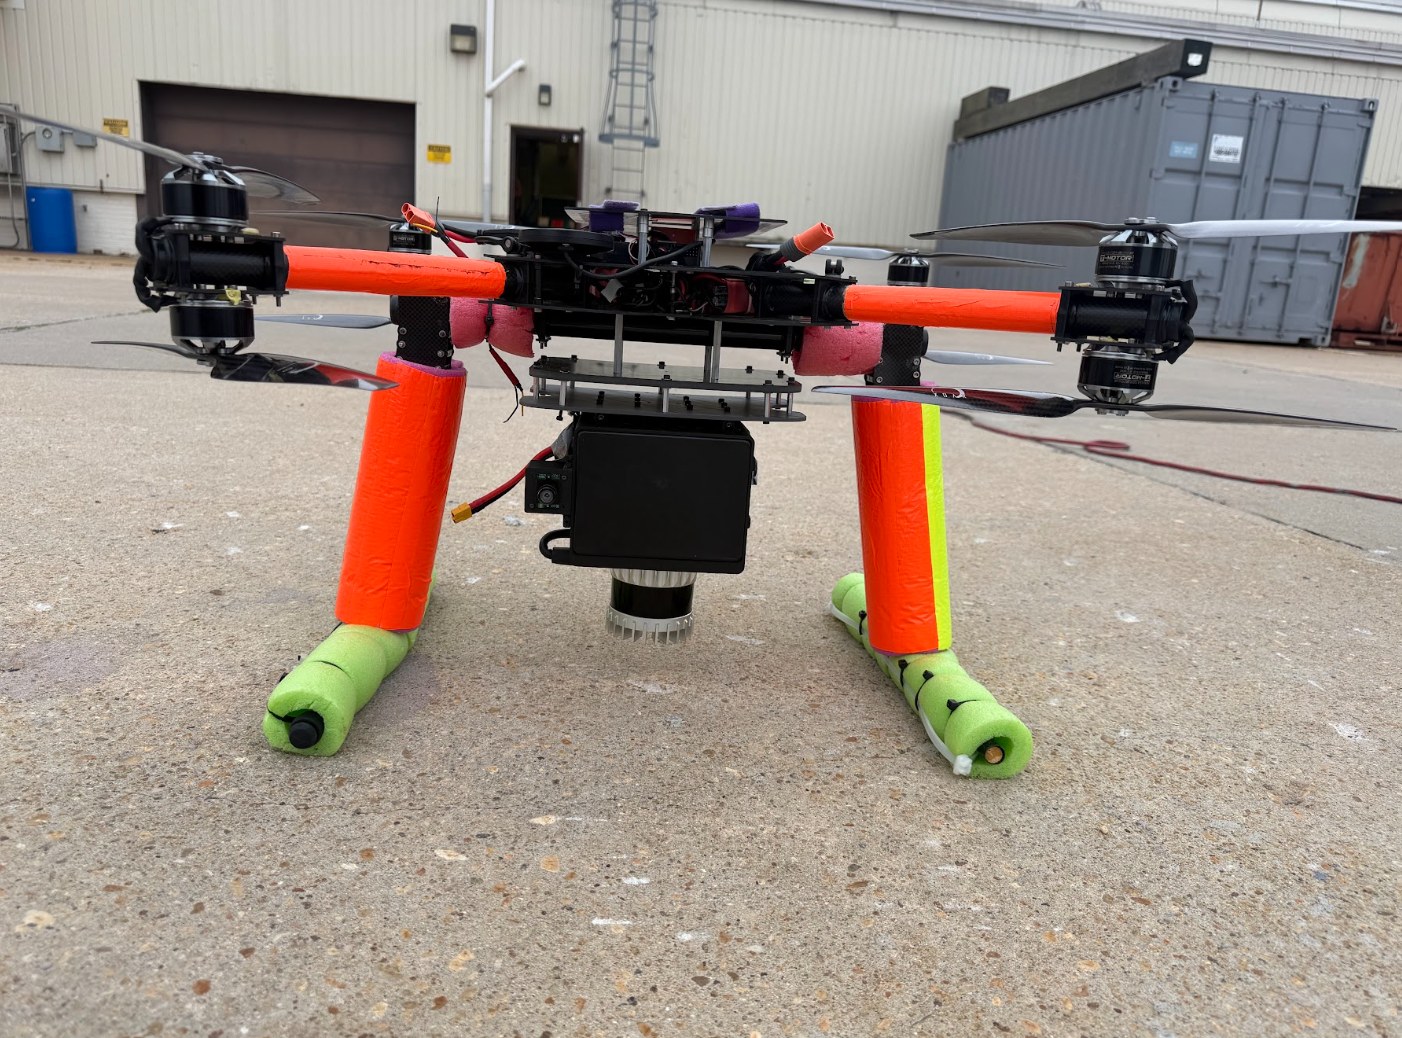
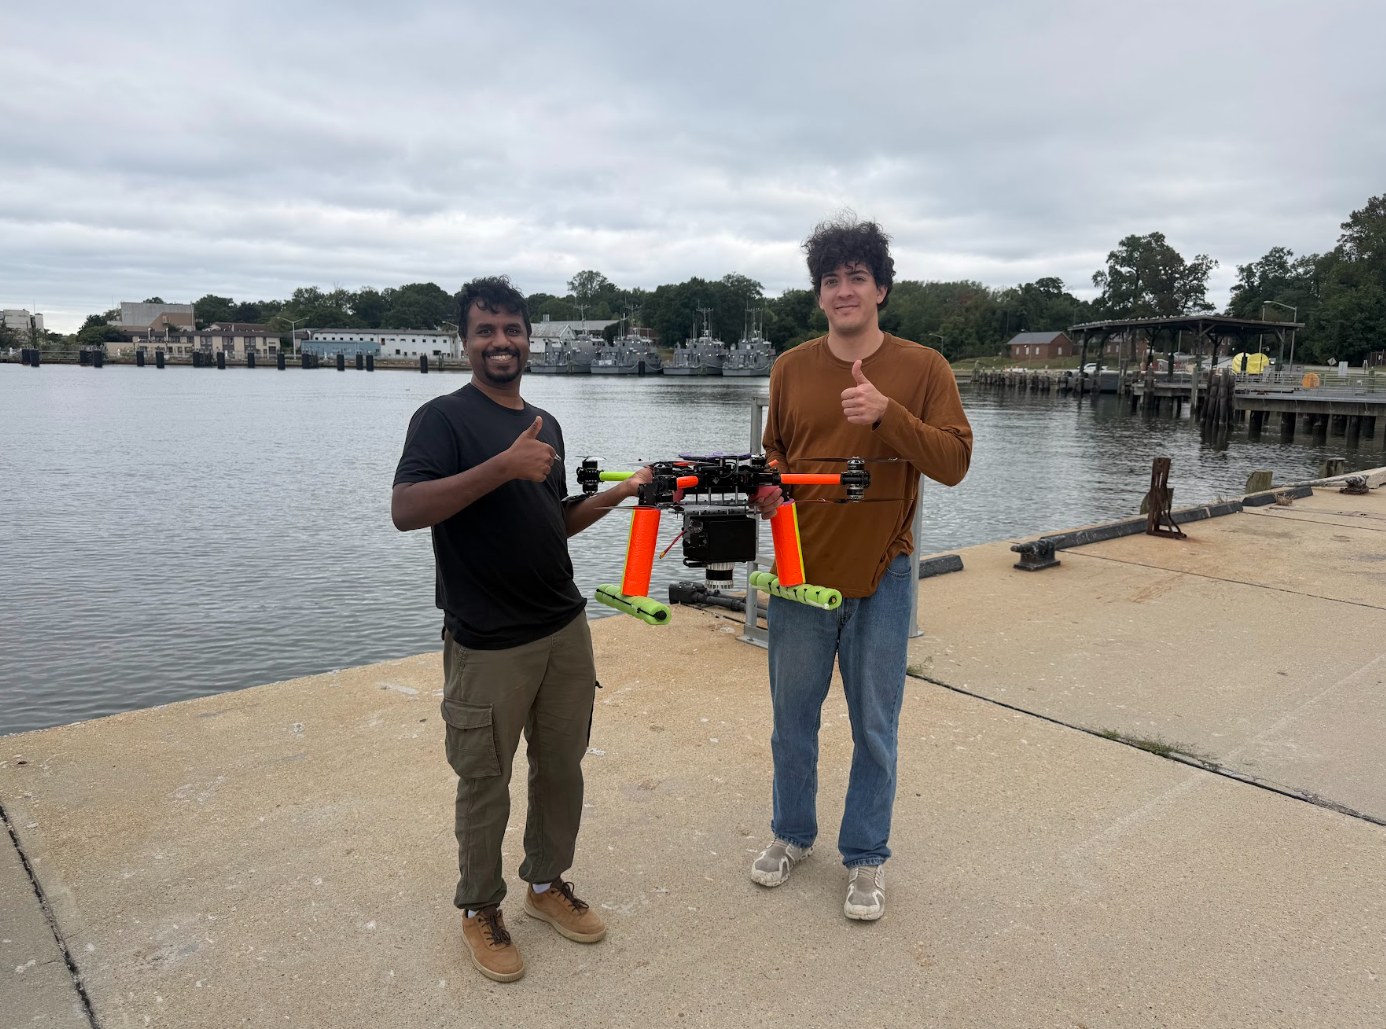
The GWU FDCL lab is participating in research in conjunction with the US Naval Academy. As part of ongoing research I helped develop the data collection system that would be mounted on the underside of a large quadcopter that would do numerous scans off the aft end of the ship.
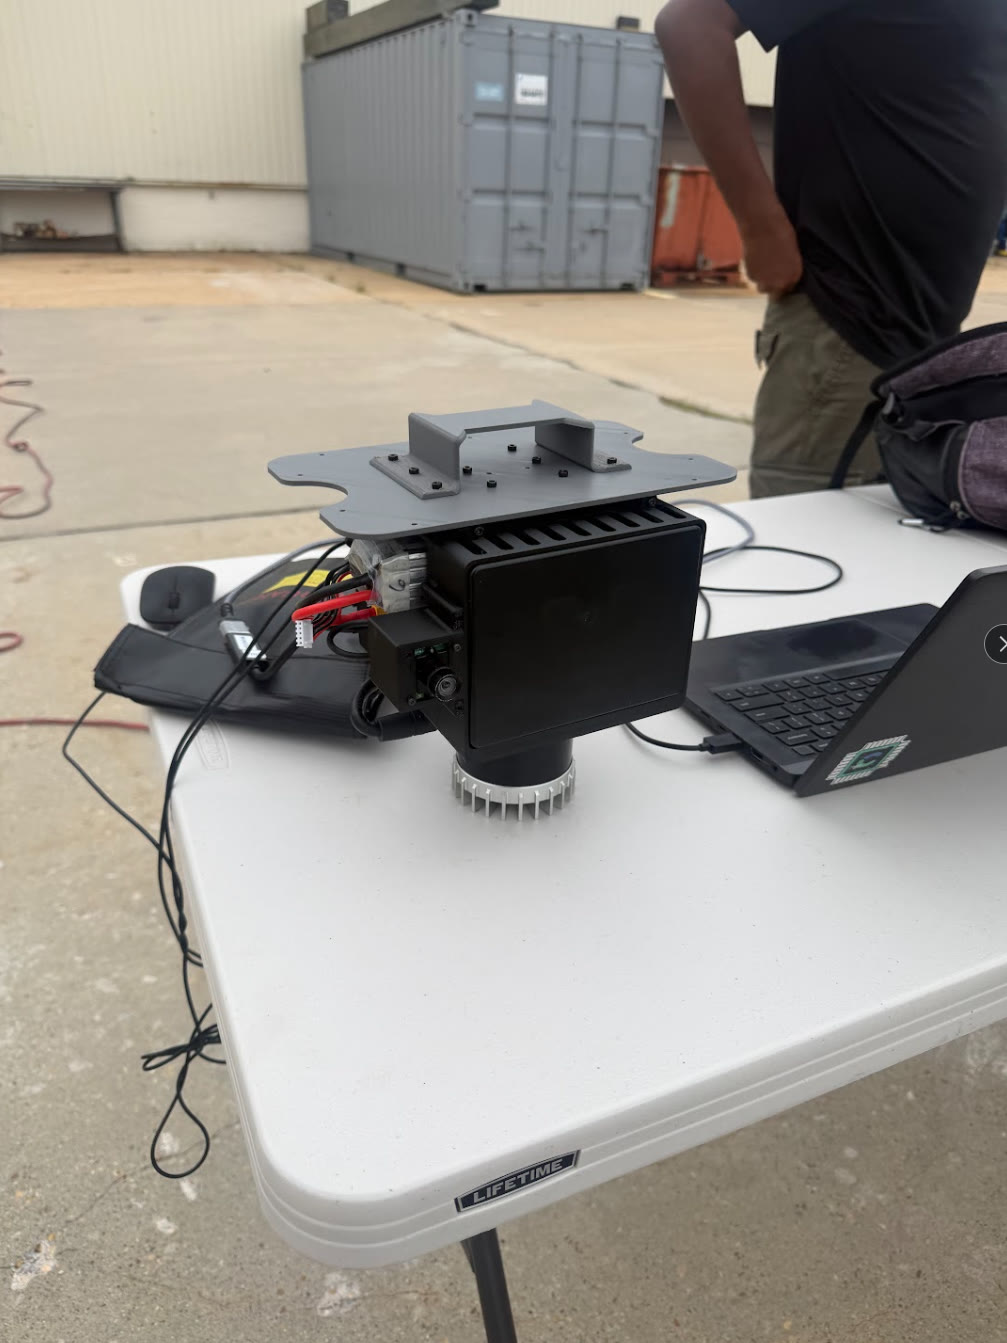
This data collection system has four different ways of sensing its environment. There is a large 4D-radar that gives you distance, velocity, direction, and height to an object. There is also a Ouster lidar mounted on the underside of the data collection system that allows us to compare the pointclouds coming from the lidar and radar. Additionally, there is a mono-camera that is capturing images of the boat as well as a VN100 imu measuring acceleration and orientation of the payload during flight.